Intuitive motion capture
Precisely captures human hand motion as raw motion data.
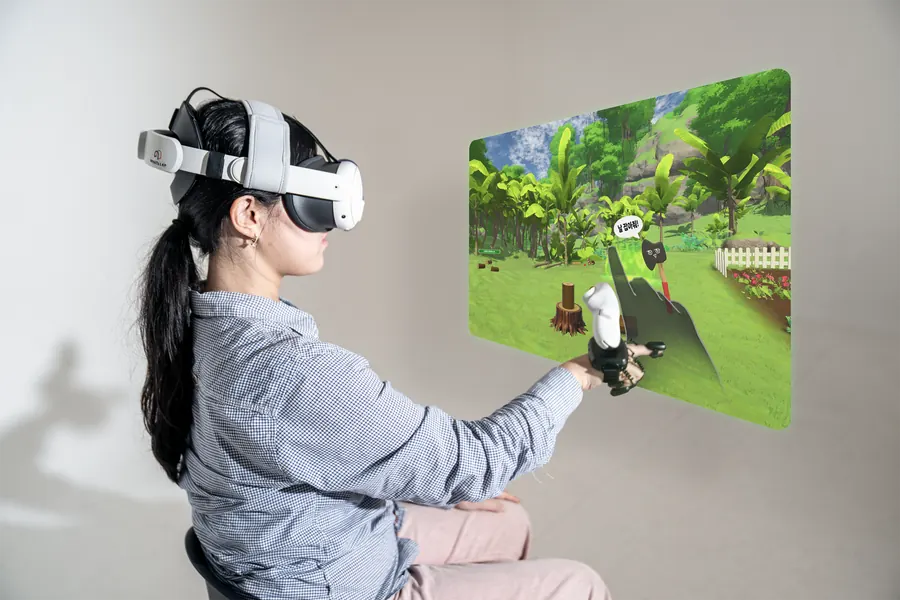
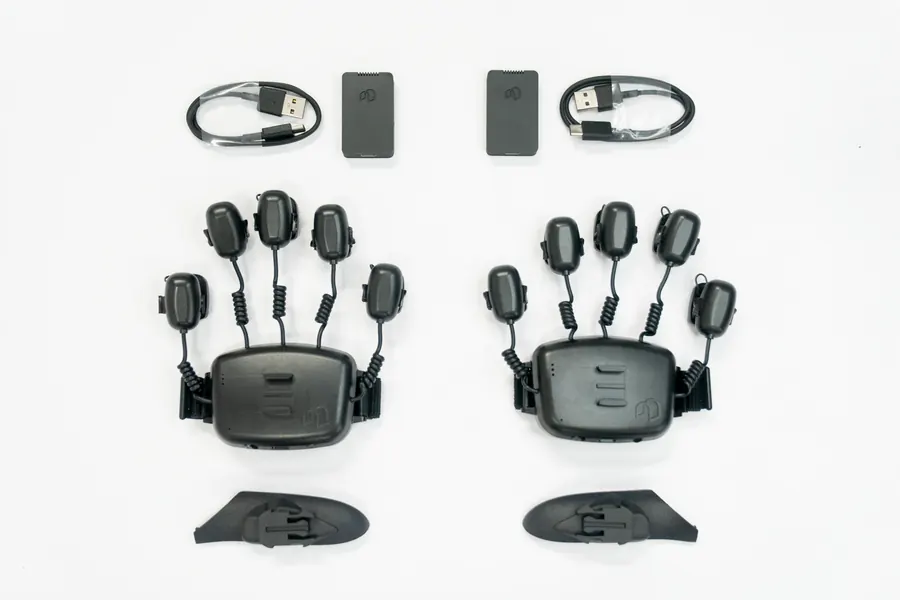
Air Glove Atlas precisely captures human hand motion and provides haptic feedback. The captured data can be used in Physical AI and immersive virtual training environments.
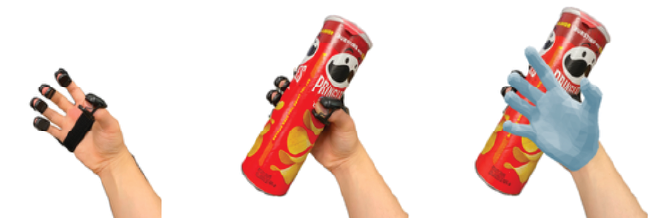
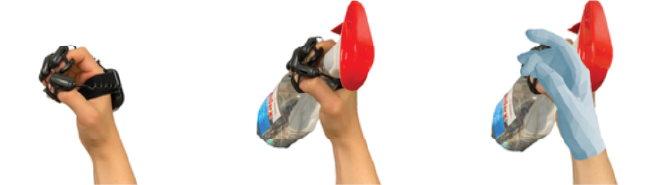
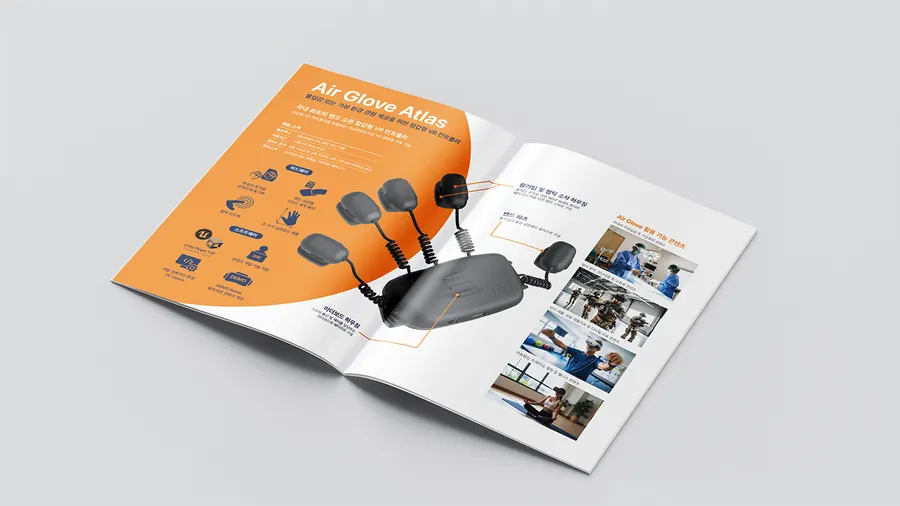
Air Glove Atlas is an open-band device that captures finger-level motion and provides haptic feedback.
Precisely captures human hand motion as raw motion data.
Turns natural hand movement into robot learning data without complex control steps.
Connects with development environments such as ROS 2, Unity, Unreal, and Isaac Sim.
An open-band glove-type interaction device that precisely captures hand movement and provides per-finger haptic feedback.
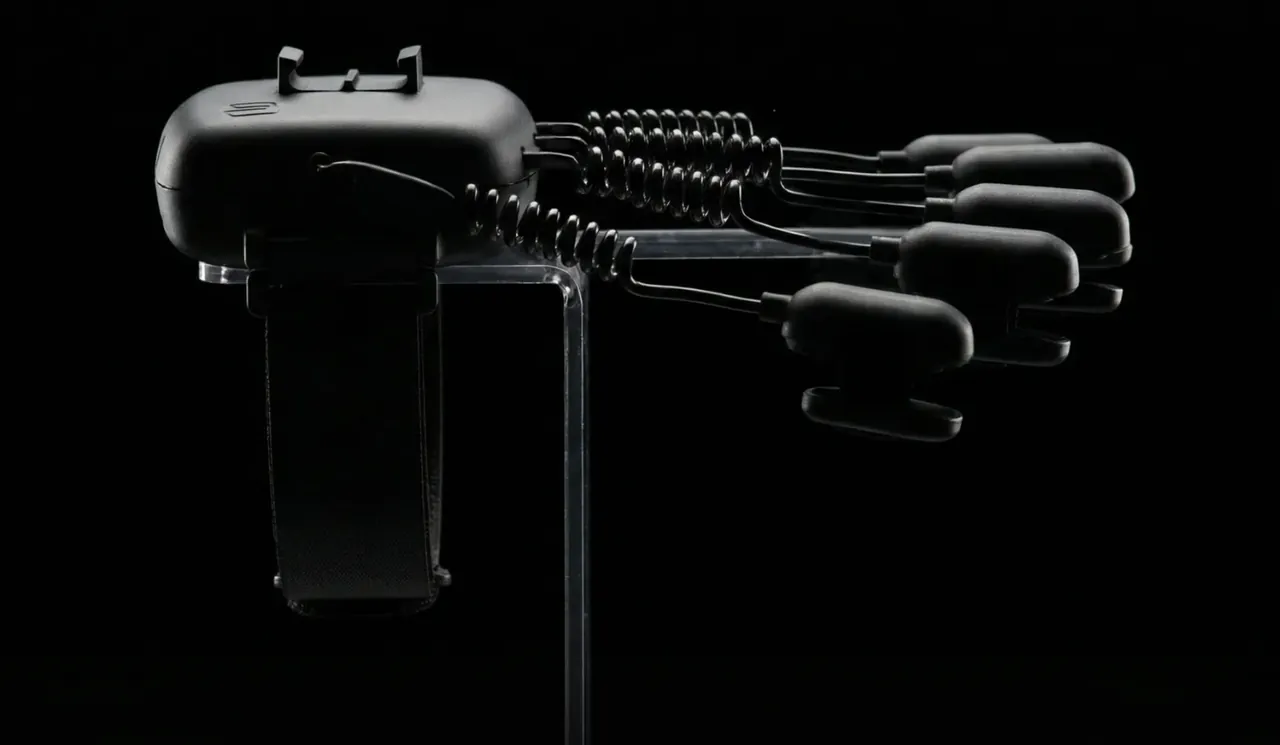
Open-band design
Fits various hand sizes

Motion tracking
Haptic feedback
Game engine integration
Development environment
Technical support
Demo scenes
Isaac Sim
ROS 2
Unity
Unreal
Humanoid robot teaching and teleoperation
Industrial remote work
Medical simulation
XR-based virtual training
Uncomfortable fit across different hand sizes
One-size design that fits a wide range of hand sizes
Discomfort during extended wear due to sweat and debris
Comfortable open-band design for long-term wear
Low tracking accuracy based on flex sensors
High accuracy powered by an in-house AHRS (IMU)
Limited abduction and adduction tracking
Abduction and adduction tracking supported
Low usability due to lack of content
Unity and Unreal content integration
Limited accessibility due to high cost
Product configuration and technical support for each deployment environment
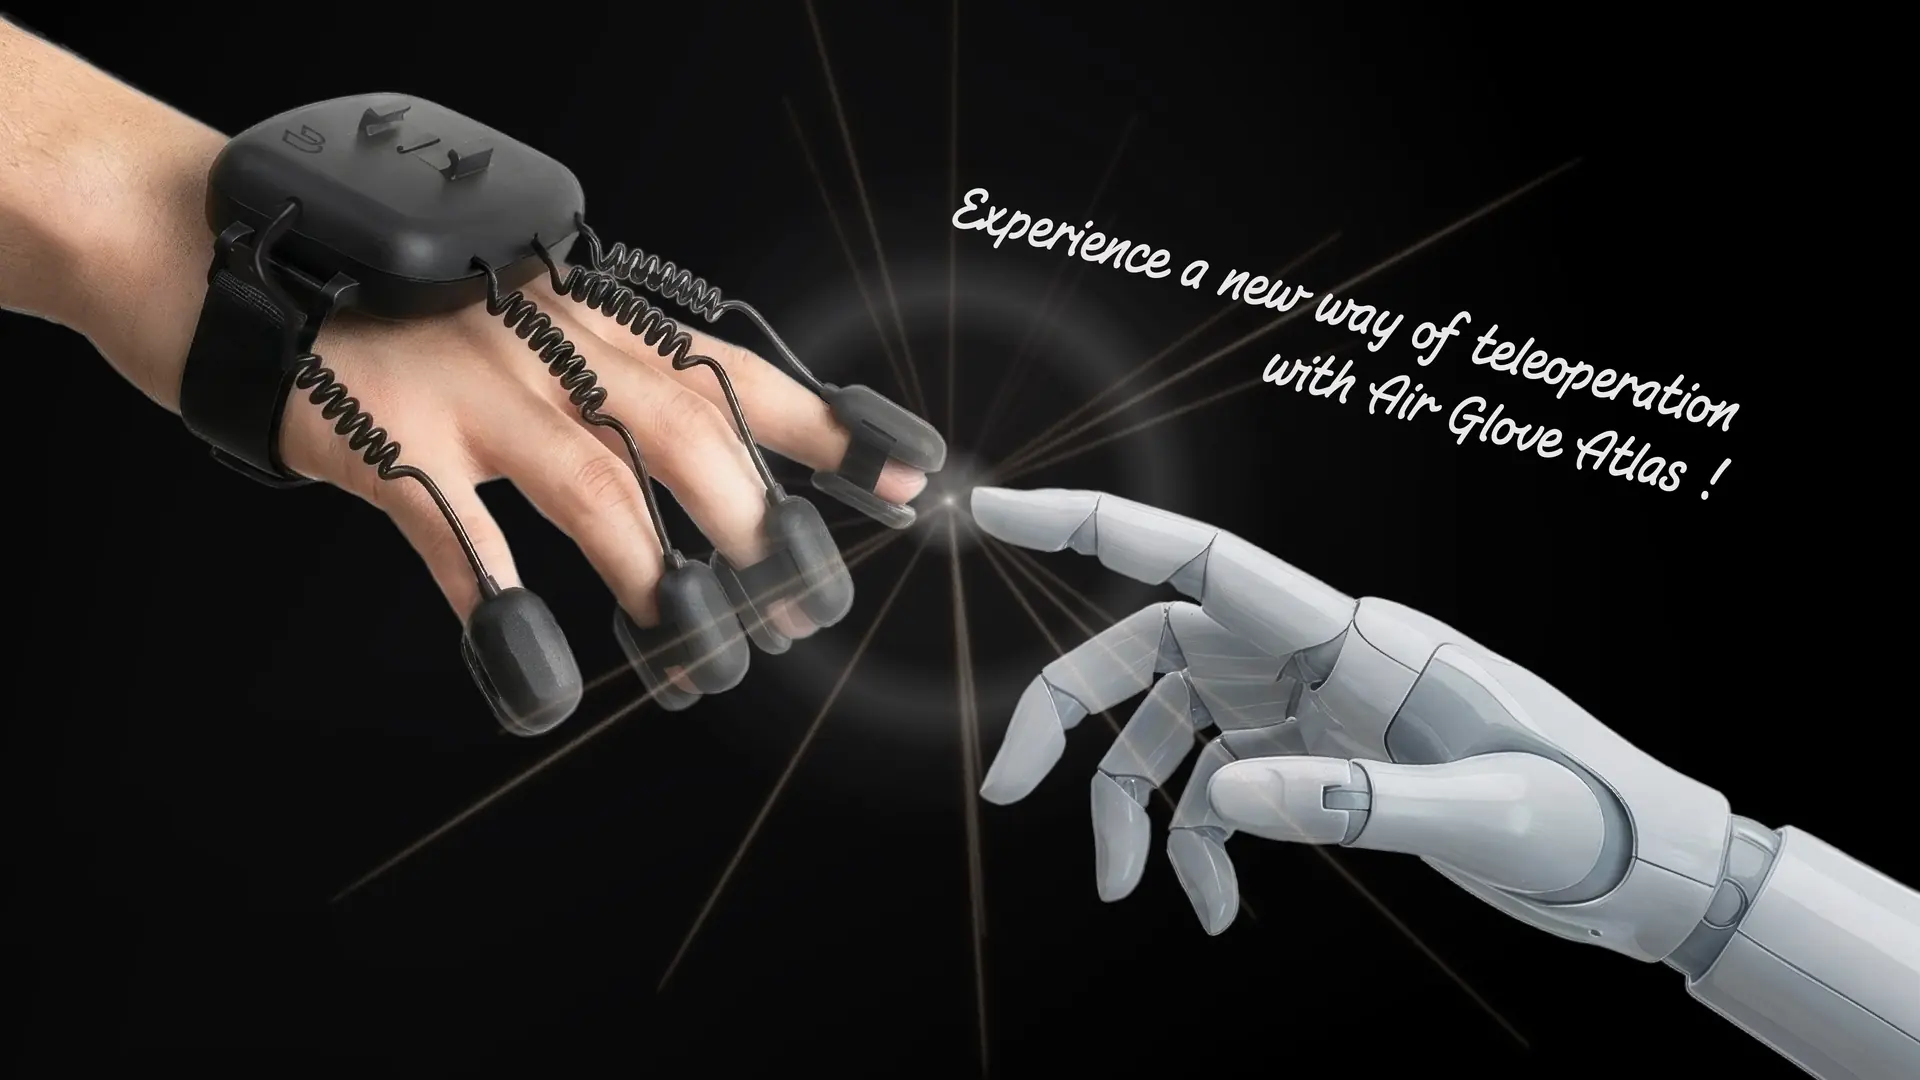
Use hand-motion and manipulation data captured with Air Glove Atlas for robot learning and simulation.
Data Pipeline
The structure connects hand-motion capture, raw data collection, simulation transfer, and deployment to robot hands.
01
Capture
Captures finger bending, finger spread, and wrist motion.
02
Collect
Stores data in a form that can support robot teaching and learning.
03
Simulate
Connects motion data to virtual environments such as ROS 2 and Isaac Sim.
04
Deploy
Extends simulation and learning results into real robot-hand control.
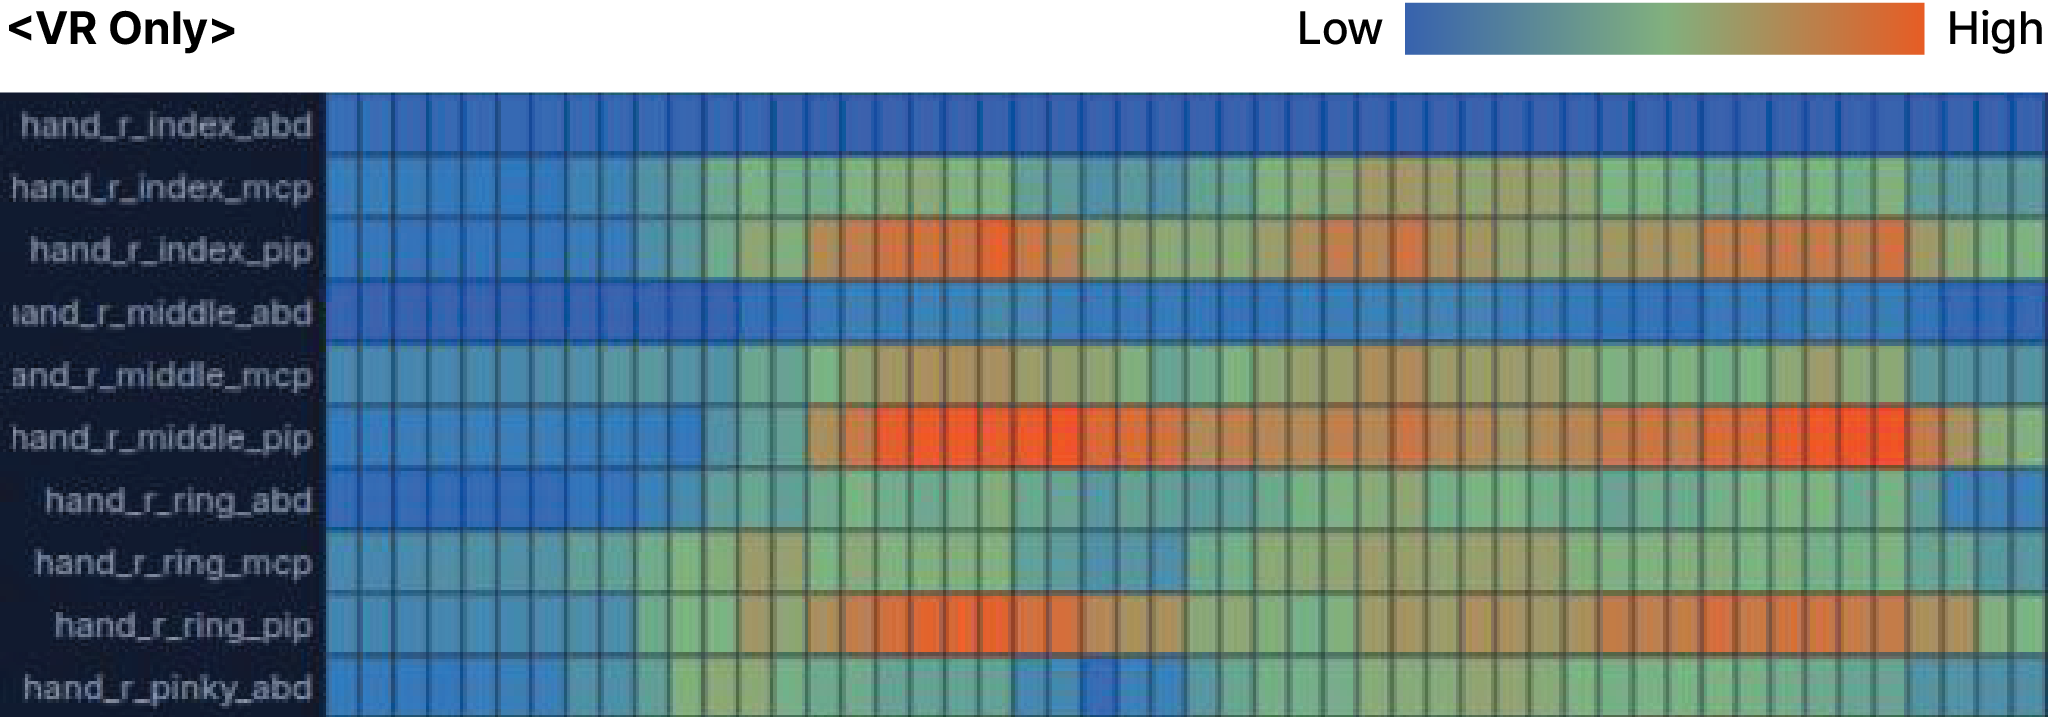
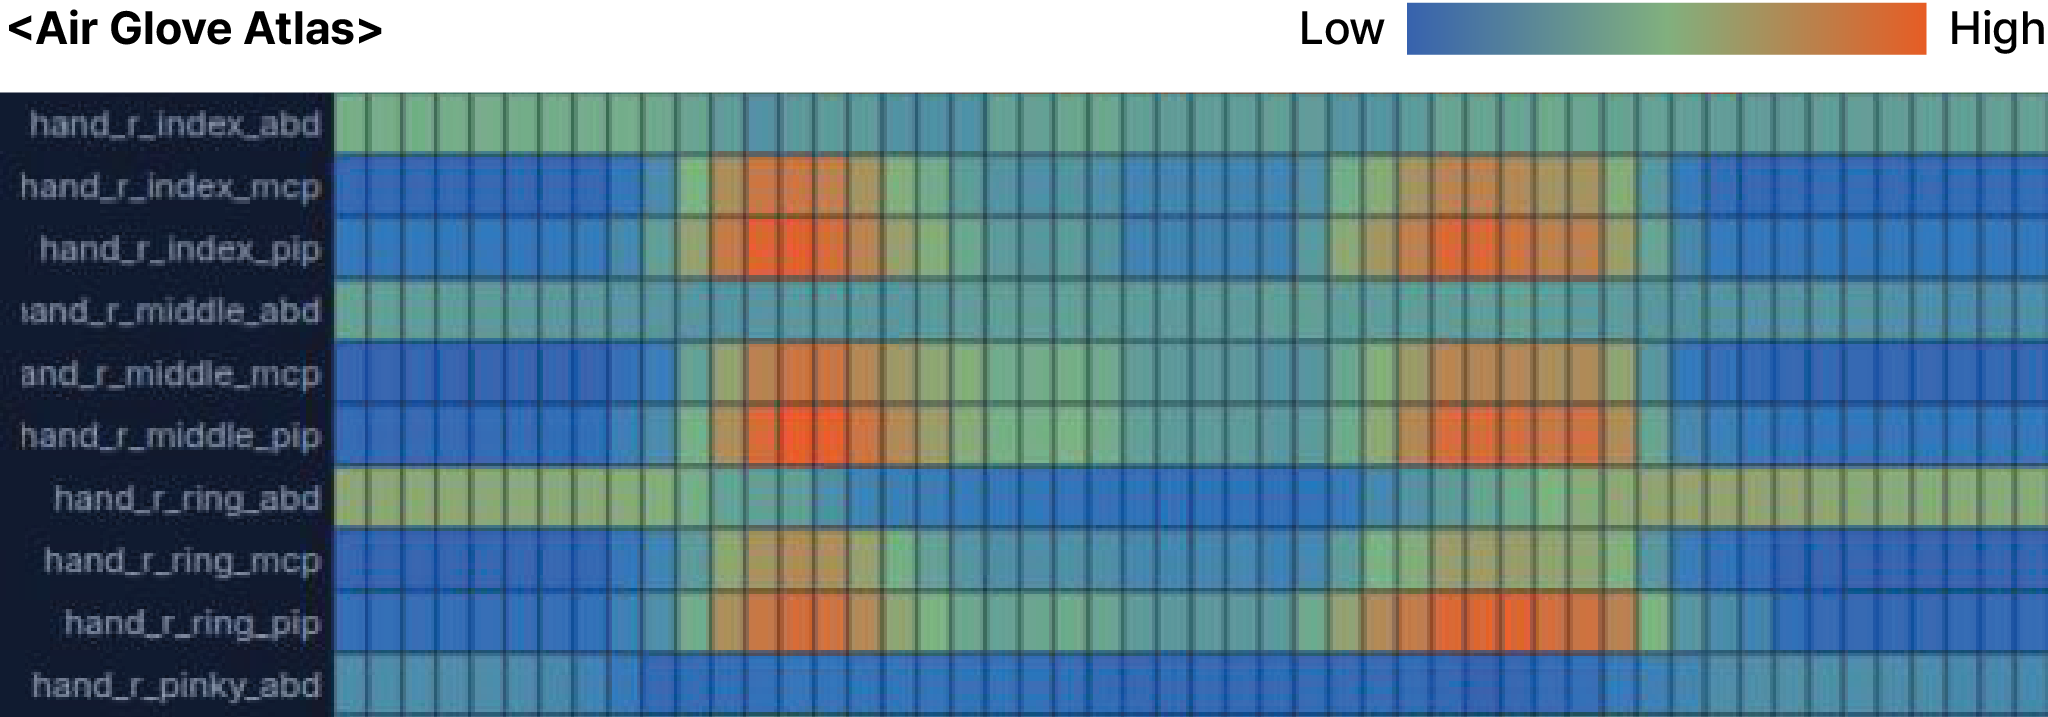
Sejong Univ. Robotics & Computer Vision Lab Research by Sejong University's Robotics and Computer Vision Lab
Teleoperation time
VR Only
Air Glove Atlas
60% less time
Teleoperation success rate
VR Only
Air Glove Atlas
10%p increase
Continuously captures hand input in occluded or low-light environments.
Supports fine-motor training such as tool use, grasping, and manipulation.
Connects quickly with existing XR content built on Unity and Unreal.
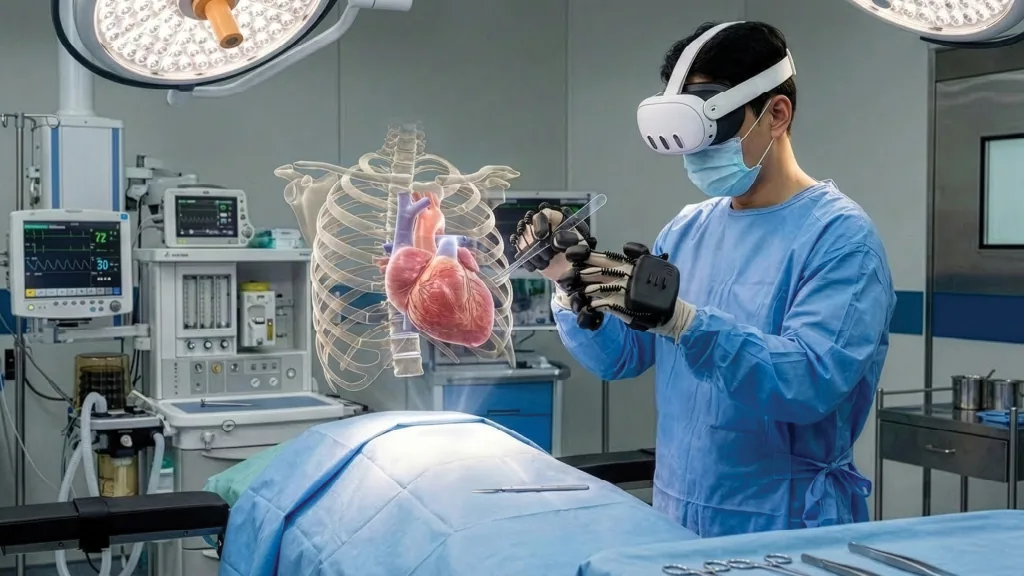
Extends medical procedures and rehabilitation training into hand-interactive XR experiences.
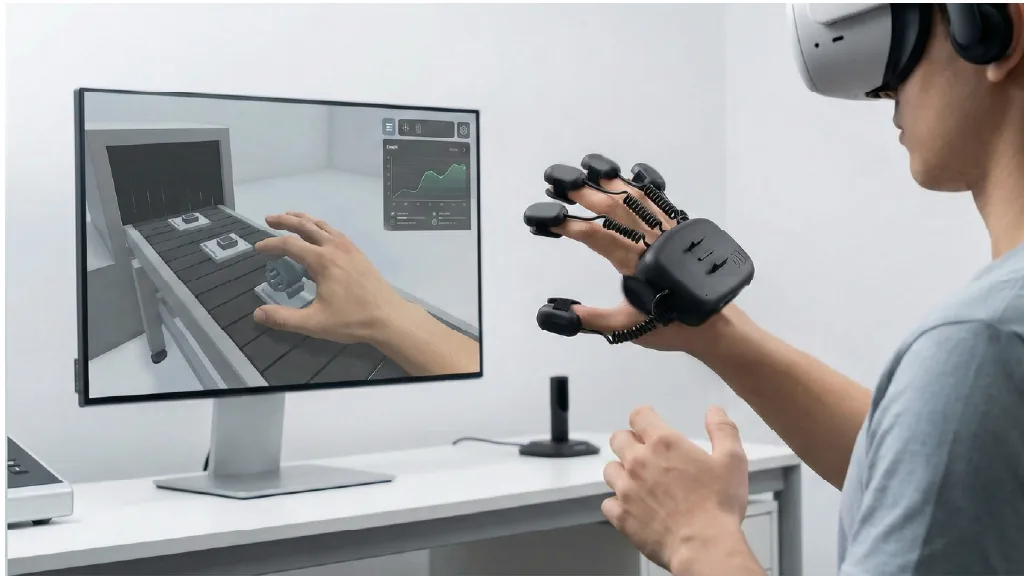
Turns equipment operation, safety training, and field procedures into repeatable virtual training content.
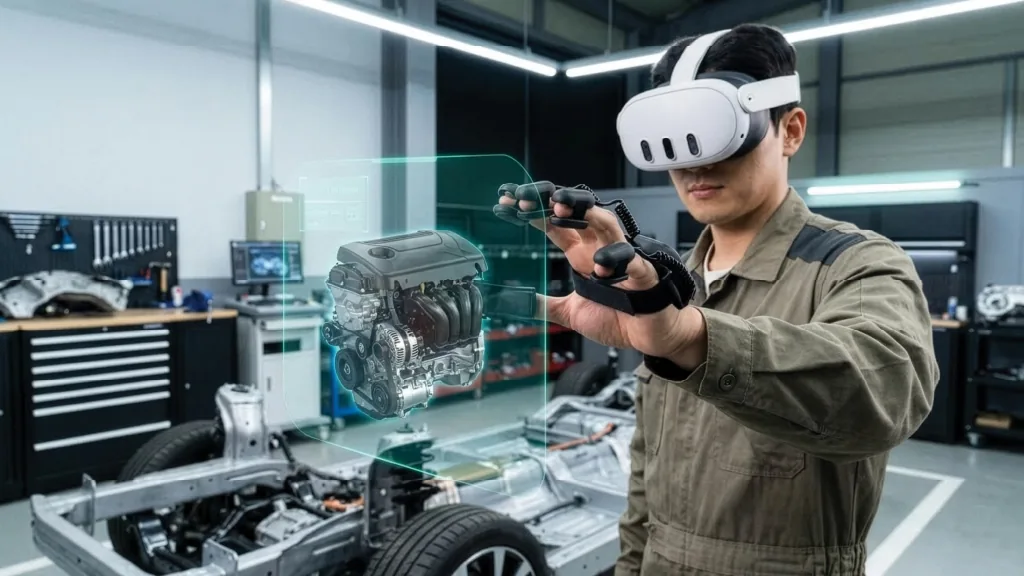
Converts tasks that require repeated practice into immersive training environments.
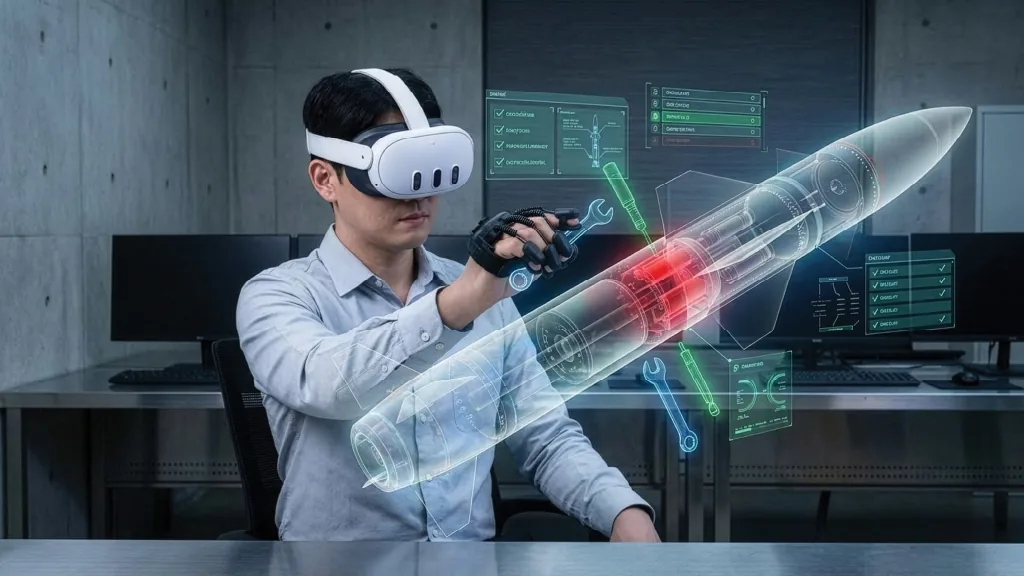
Creates immersive practice content that learners can manipulate directly by hand.
We can review product and pipeline configurations for robot learning, XR training, medical rehabilitation, and related use cases.