SDK & API
Air Glove data. In your development environment.
We are preparing SDK and API tools to bring Air Glove hand motion and pose data into robotics and simulation environments.
SDK & API · Public release in preparation
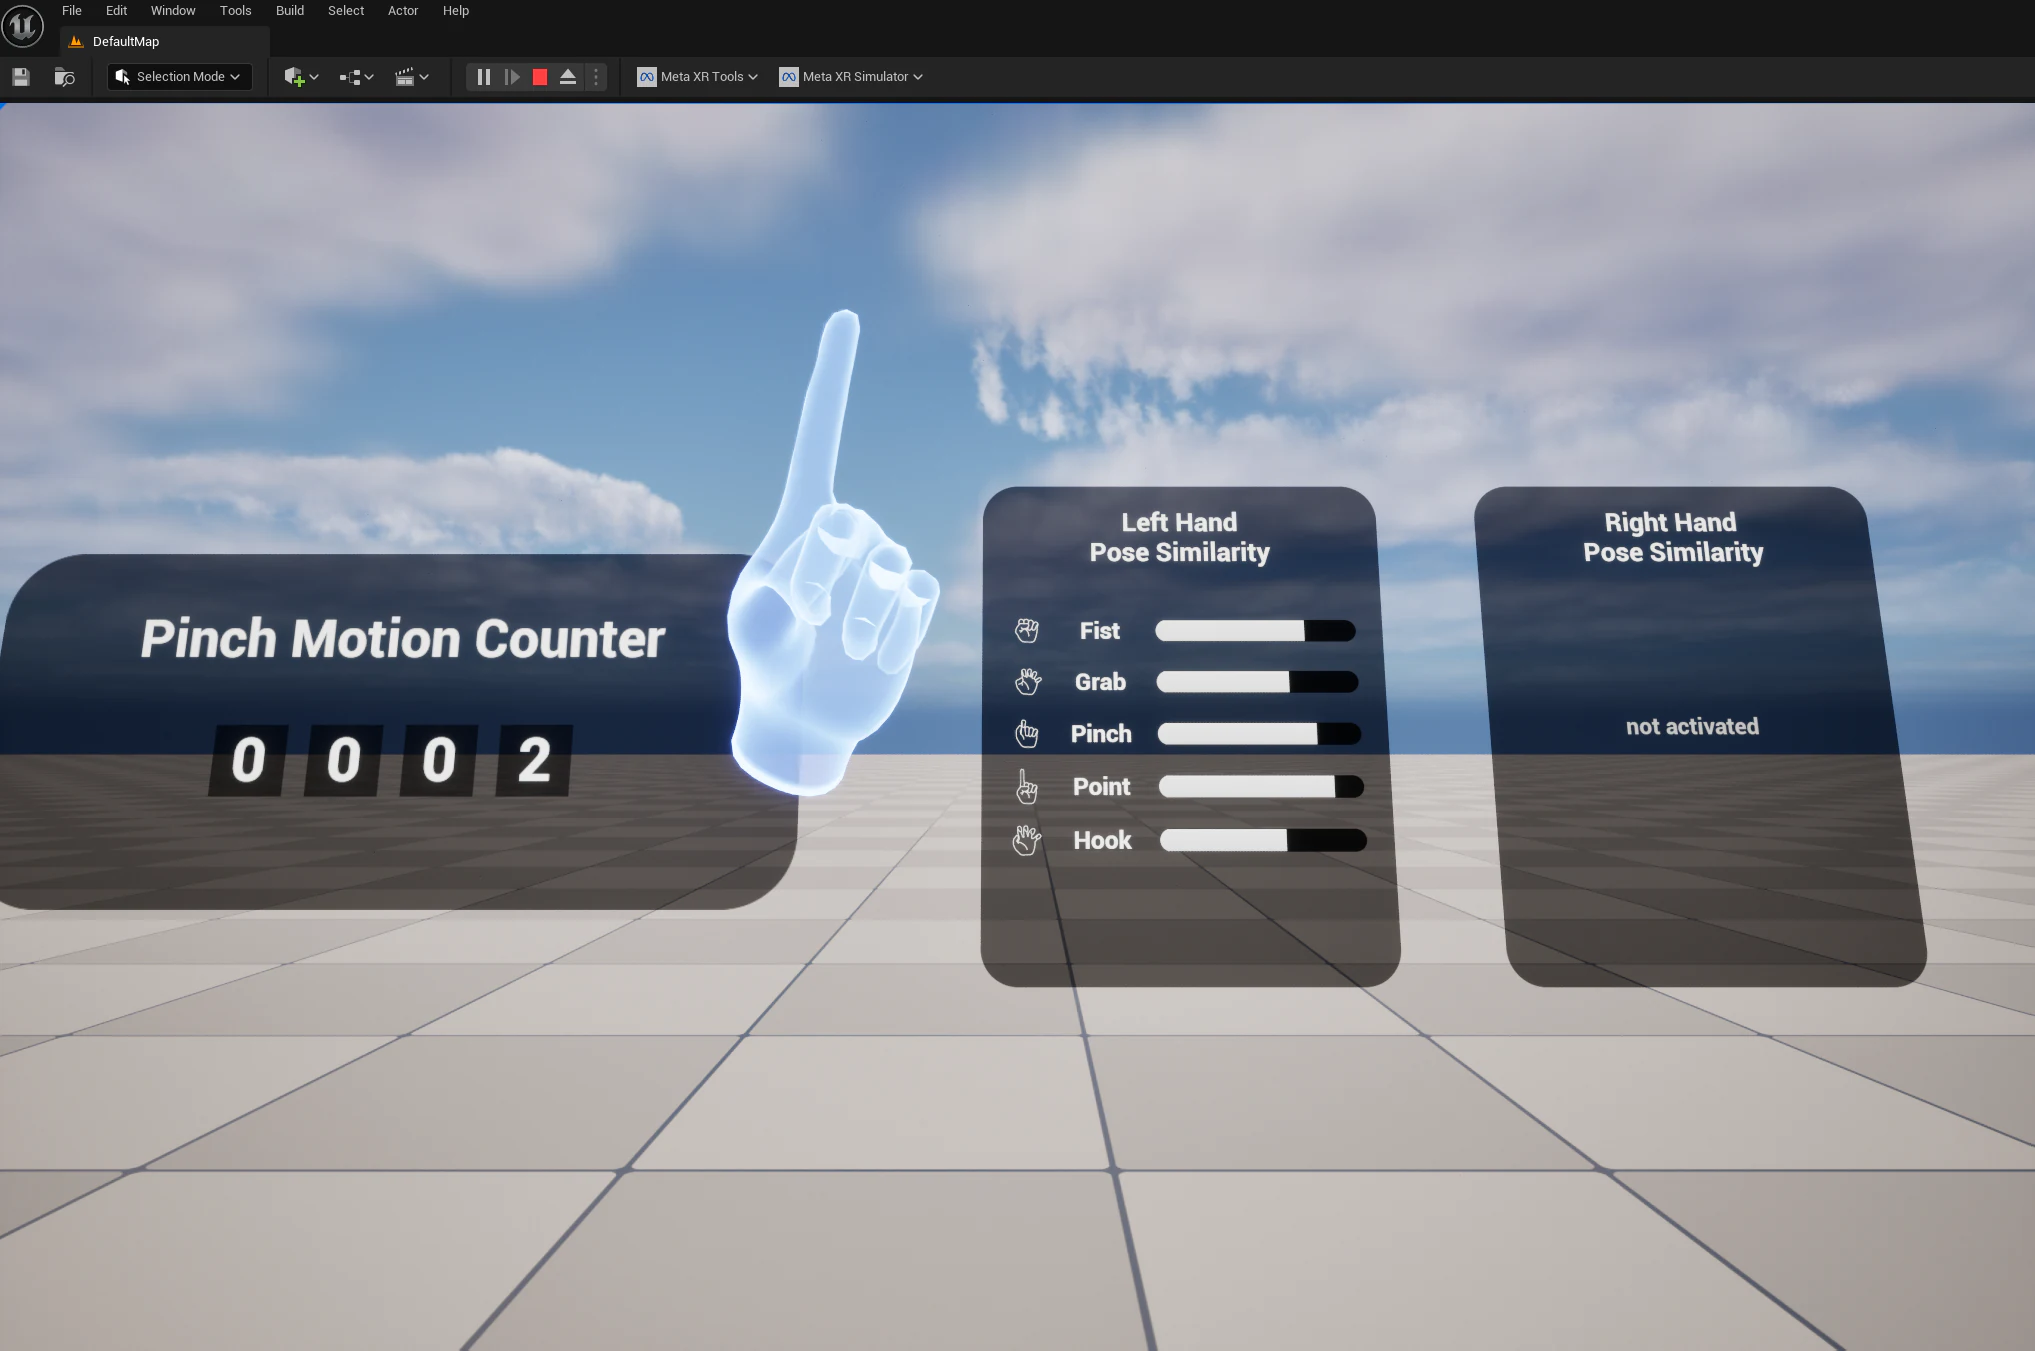
Unreal Engine integration example
Hand motion visualization and pose similarity
What the SDK does
Connect hand-motion data collected and reconstructed in Spine to robots and development environments. SDKs and APIs support teleoperation, simulation, and learning-data collection.
-
Access hand-motion data
Connect and calibrate Air Glove in Spine. SDKs and APIs make the processed hand-motion and pose data available to your application.
-
Retarget to robot hands
Adapt hand motion captured with Air Glove to a robot hand's structure for use as robot joint commands and teleoperation input.
-
Integrate with your tools
Use hand-motion data in Unity, Unreal Engine, Isaac Sim, and ROS 2, with project-specific customization, technical support, and onboarding.
Supported robot hands
Use Air Glove hand-motion data for robot-hand teleoperation and data collection.
Retargeting software is also available for other hands. Contact us to confirm support for your robot-hand model and integration requirements.
Supported software
Bring hand-motion data into your development environment, from interactive content to robot control and simulation.
-
Unity
XR and interactive content
-
Unreal Engine
Visualization and simulation
-
Isaac Sim
Robotics simulation
-
ROS 2
Robot control and data integration
Confirm supported versions and available features for your Air Glove product and project environment.
FAQ
Before you start integrating with the SDK and API.